About Me

I am a Ph.D. student in Mechanical Engineering at Purdue University.
My research focuses on developing generalizable robotic perception, learning, and manipulation methods for complex and underexplored environments. In particular, I am interested in using challenging environments, including precision manufacturing, as testbeds for advancing generalizable robotics rather than developing task-specific automation systems.
Previously, I was with INRoL, where my research focused on generalizable navigation and scene understanding for mobile robots. I am currently with LAMM, where I use complex manufacturing environments as a testbed for developing generalizable robotic perception, learning, and manipulation methods, particularly by tackling challenging edge cases that are often underexplored in conventional robotics settings.
Research Interests
Robot Perception · 3D Scene Reconstruction · Robot Learning · Dexterous Manipulation
Publications
Journal Articles
Toward Provably Safe AI-Driven Perception and Motion Planning for Robotic Manufacturing: A Review.
Journal of Manufacturing Systems, 2026.
H. Lee, Y. Sim, J. Jang, B. Yoon, et al.
Fast and Robust Online Initialization of Monocular Visual-Inertial Odometry via One-Dimensional Cost Approximation.
IEEE Transactions on Robotics, 2026.
J. Kang, J. Choe, D. Kong, B. Yoon, et al.
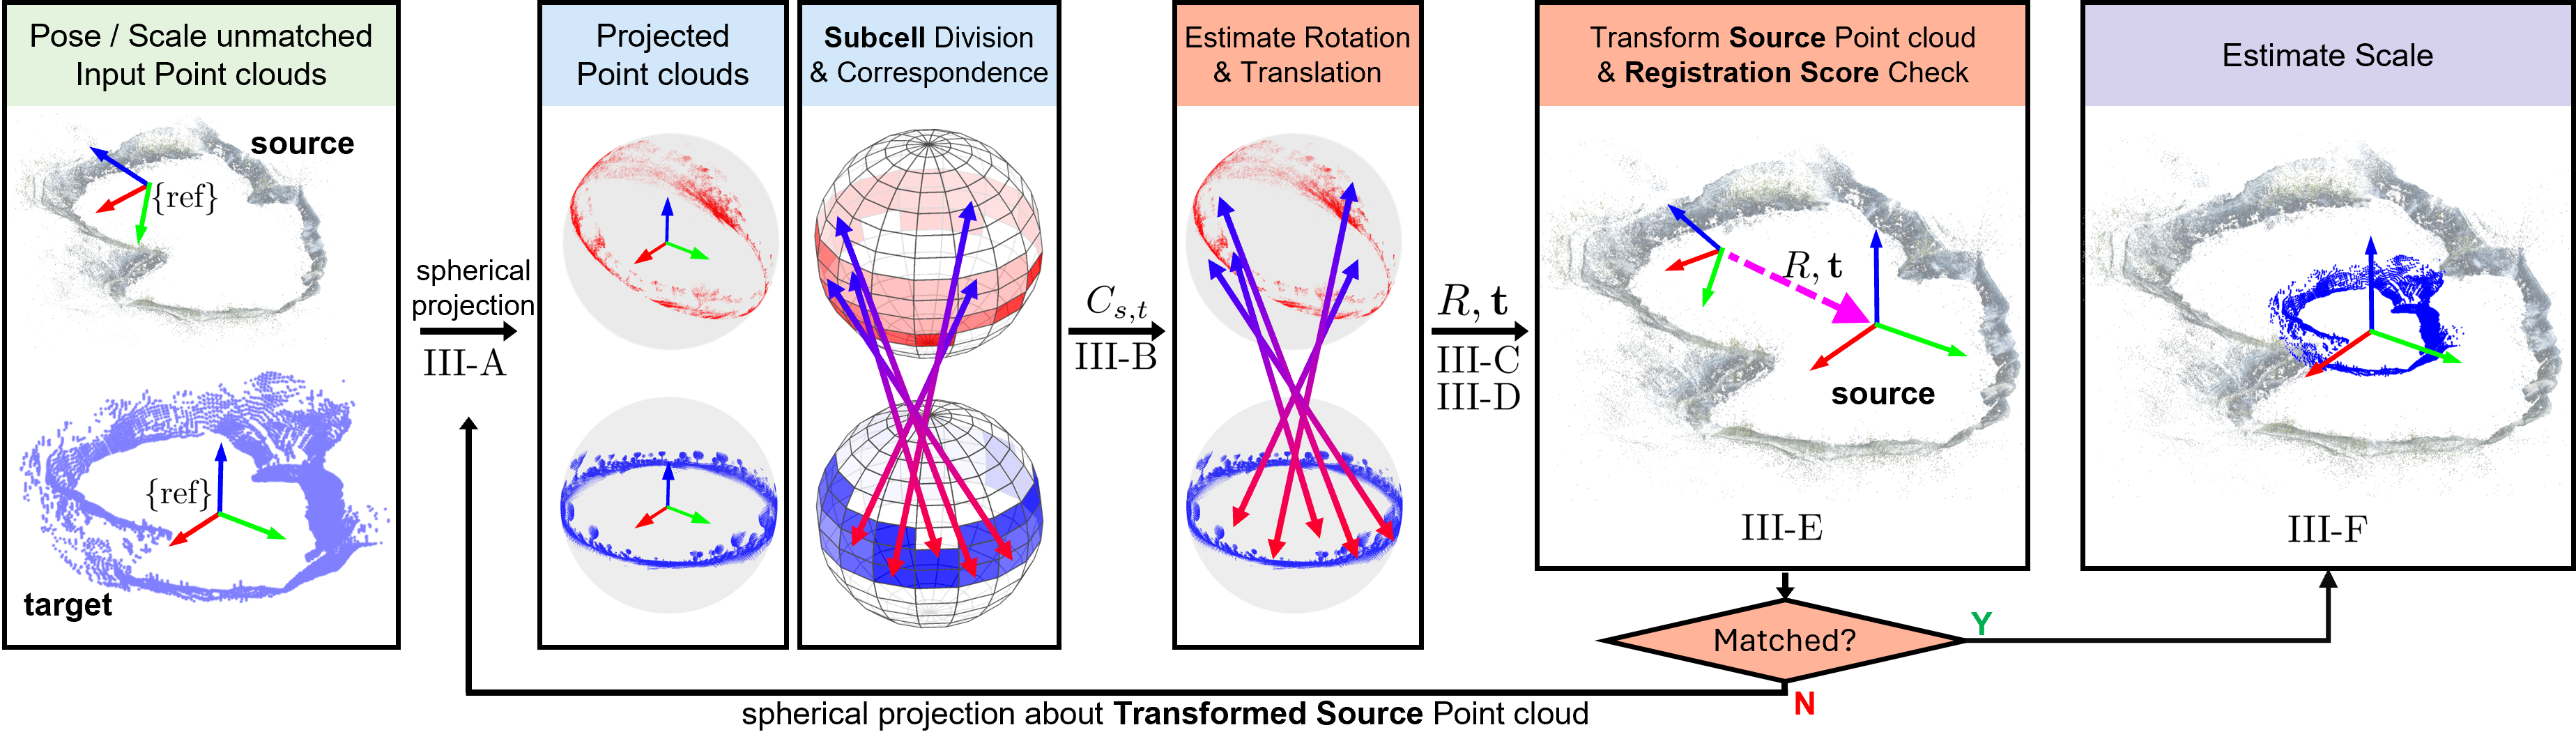
Directional Correspondence Based Cross-Source Point Cloud Registration for USV-UAV Cooperation in Lentic Environments.
IEEE Robotics and Automation Letters, 2025.
B. Yoon, S. Hong, D. Lee.
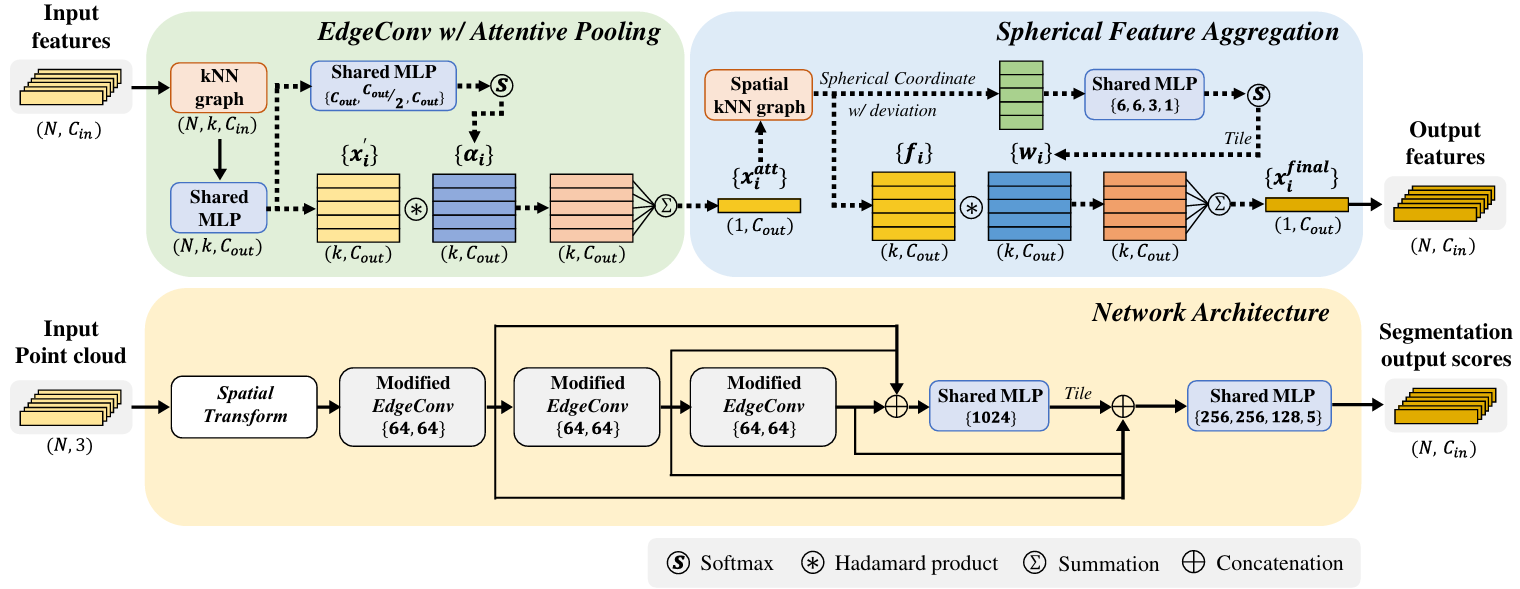
Machine Learning-Aided Three-Dimensional Morphological Quantification of Angiogenic Vasculature in the Multiculture Microfluidic Platform.
BioChip Journal, 17, 357–368, 2023.
W. Lee, B. Yoon (Co-first), et al.
Conference Papers
LiDAR-Integrated Coarse-to-Fine Optimization for Geometrically Consistent Triangle Splatting from Mobile Robots.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 (Accepted).
B. Yoon, et al.
Paper and code coming soon.
UWB-Based Localization System Considering Antenna Anisotropy and NLOS/Multipath Conditions.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024.
T. Kim, B. Yoon, D. Lee.
T. Kim, B. Yoon, D. Lee.
UWB-Based Localization System Considering Antenna Anisotropy and NLOS Conditions.
Institute of Control, Robotics and Systems (ICROS), 2024.